Micah Reich
I'm an aerospace GNC engineer at a stealth startup in San Francisco.
I recently completed my M.S. in Robotics at Carnegie Mellon University, where I was advised by
Zac Manchester in the Robotic Exploration Lab.
My work focuses on numerical optimization for robotics and aerospace: trajectory optimization, contact-implicit planning, and guidance, navigation, and control.
Before that, I received my B.S. in Computer Science with a concentration in robotics from CMU's School of Computer Science.
Previously, I have interned on GNC teams at SpaceX, Zipline, and Anduril.
Github
LinkedIn
micahreich02 at gmail dot com
Aug 2026
Joined a stealth startup in San Francisco as an Aerospace GNC Engineer.Aug 2026
Completed my M.S. in Robotics at CMU. My thesis, An On-Manifold Approach to Solving Mathematical Programs with Complementarity Constraints, is published as CMU-RI-TR-26-70.Apr 2026
Released Complementarity by Construction and the open-source Marble solver, with Arun Bishop and Zac Manchester.Jun 2025
Starship GNC and analysis intern at SpaceX, working on entry, landing, and catch of the Starship second stage.Jan 2025
Started my M.S. in Robotics at CMU, advised by Zac Manchester.Dec 2024
Graduated from CMU with a B.S. in Computer Science (robotics concentration).May 2024
SLAM research intern at Collaborative Robotics.Jan 2024
GNC intern at Zipline, working on control of a hybrid fixed-wing VTOL delivery drone.May 2023
Robotics software intern at Anduril Industries.May 2022
Mobile robot controls intern at Milwaukee Tool.Aug 2021
Started studying Computer Science at CMU.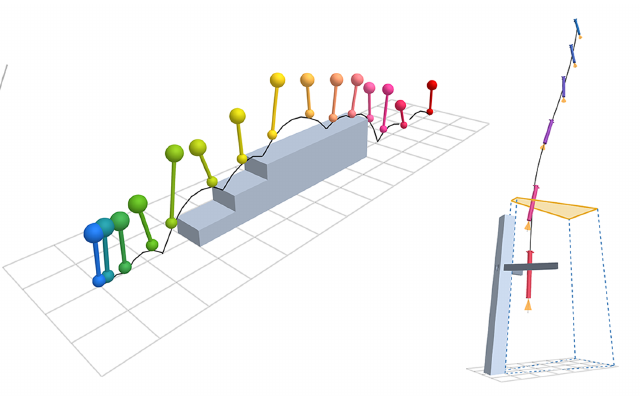
Complementarity by Construction: A Lie-Group Approach to Solving Quadratic Programs with Linear Complementarity Constraints
Arun L. Bishop, Micah I. Reich, Zachary Manchester
ICRA 2027, IEEE RA-L, ICRA 2026 Workshops (FOR, CR2)
IEEE •
arXiv •
PDF •
Code
An On-Manifold Approach to Solving Mathematical Programs with Complementarity Constraints
Micah Reich
Master's Thesis, Carnegie Mellon University, 2026 (CMU-RI-TR-26-70)
Webpage •
PDF •
Code
Robotic Lawn Mower
International Patent Application WO2024059614A1 (pending), Milwaukee Tool
Patent
Tartan Autonomous Underwater Vehicle Design and Implementation of TAUV-22: Kingfisher
T. Chemel, J. Duncan, S. Fisher, R. Jain, R. Morgan, K. Nikiforova, M. Reich, et al.
TartanAUV technical report
UAV Controls
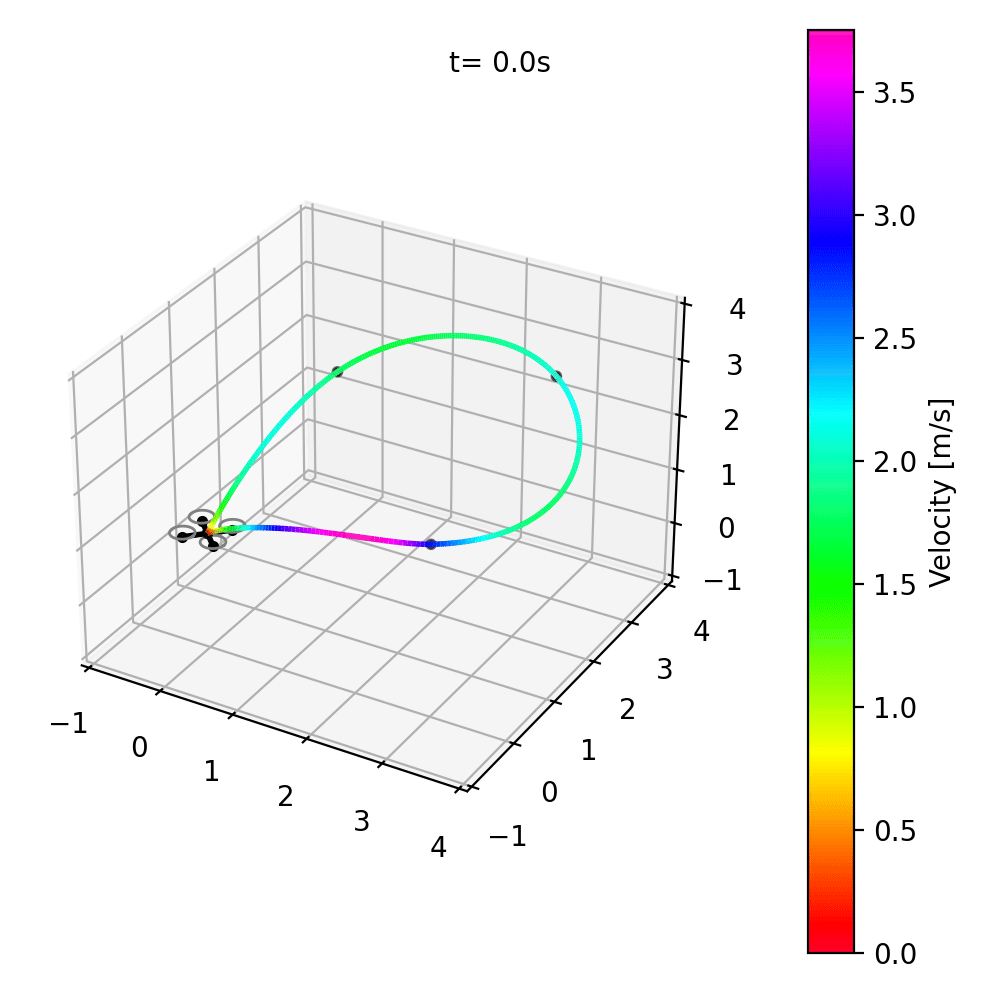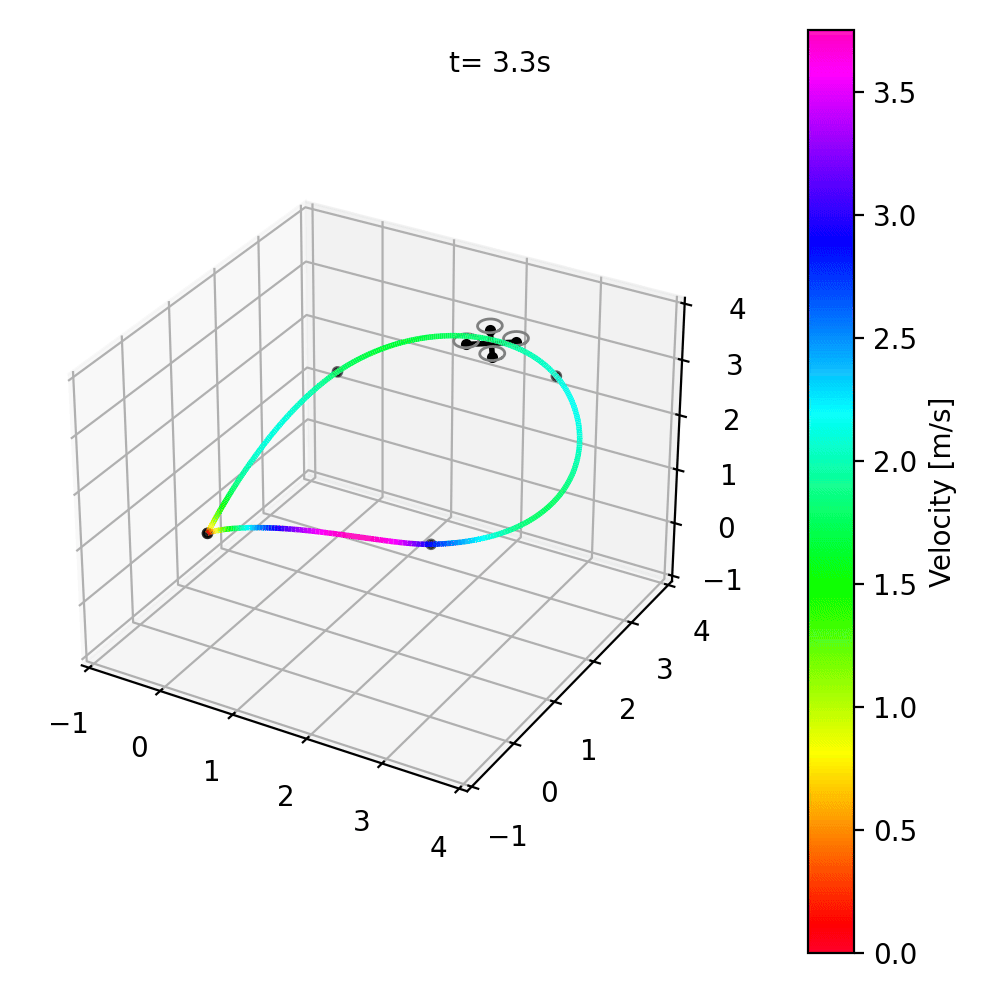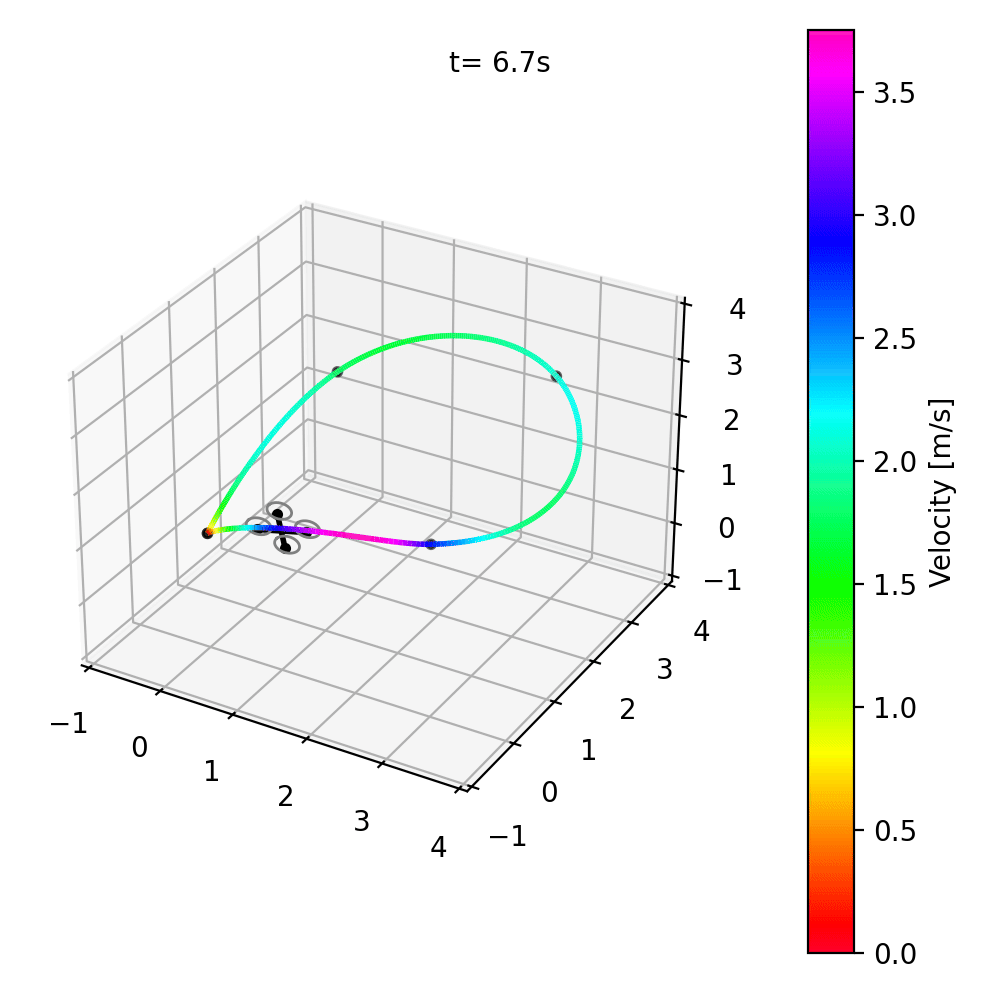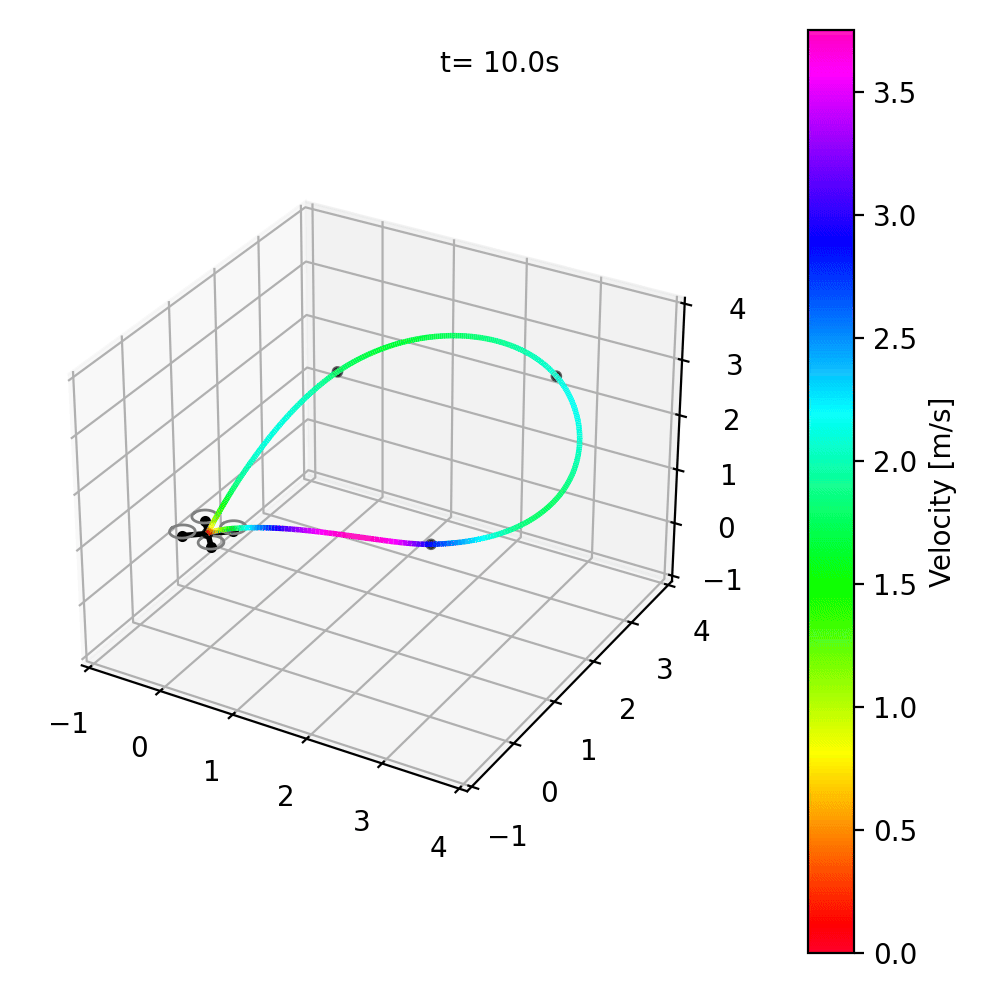
Controllers, dynamics models, and planners for quadrotor UAVs implemented from research papers, including geometric control with recovery from a 180° roll, waypoint following, and minimum-snap trajectory tracking.
Code
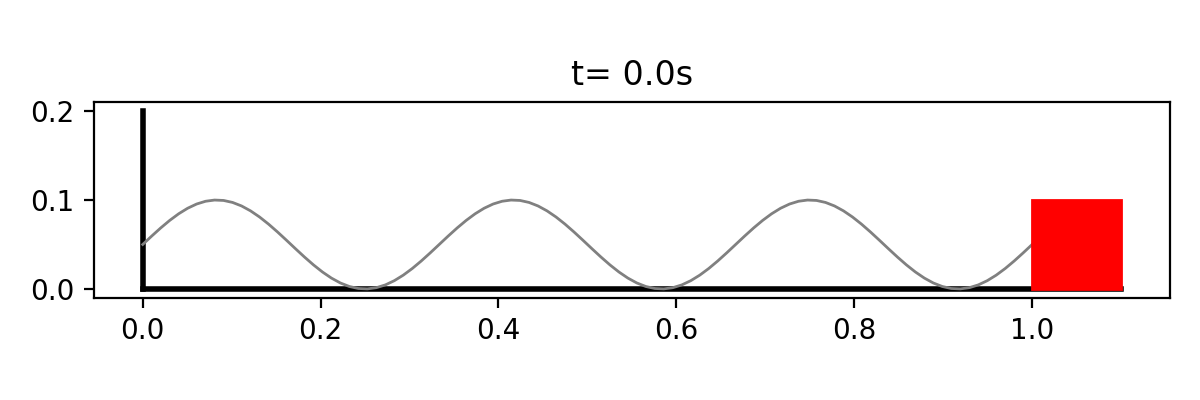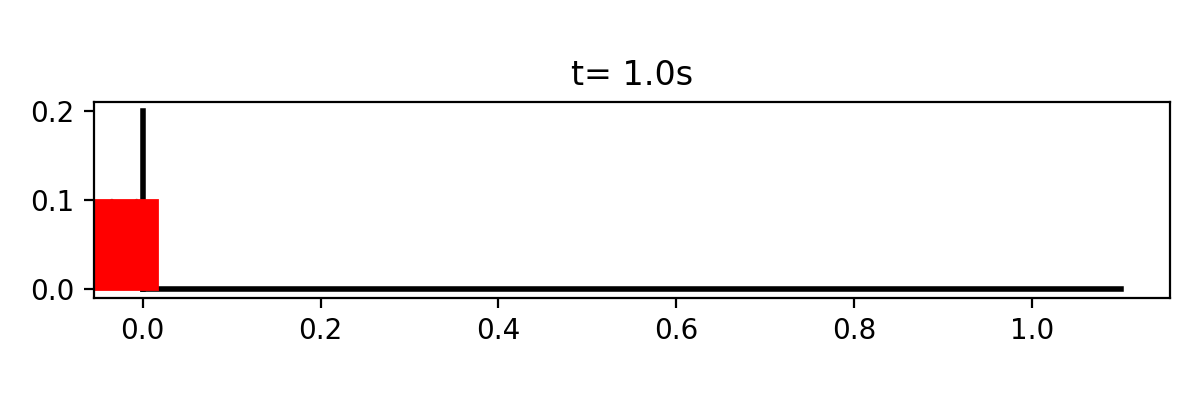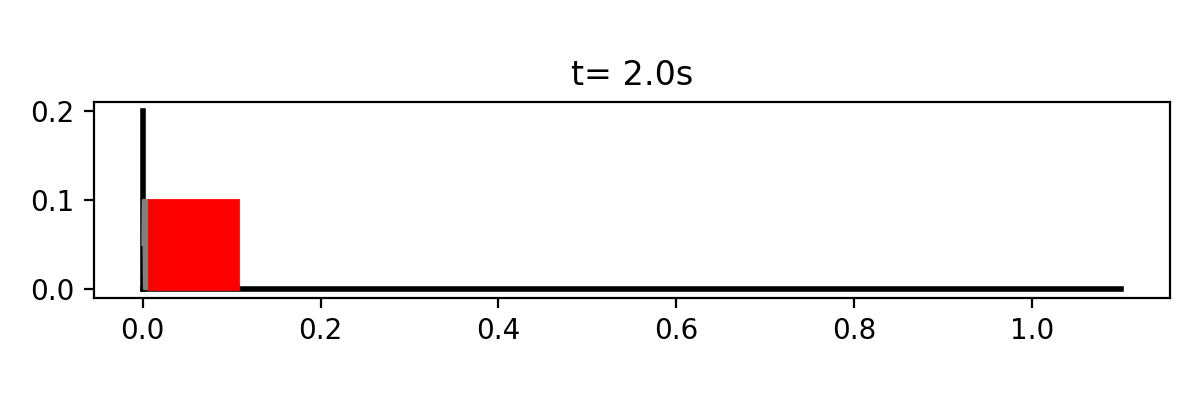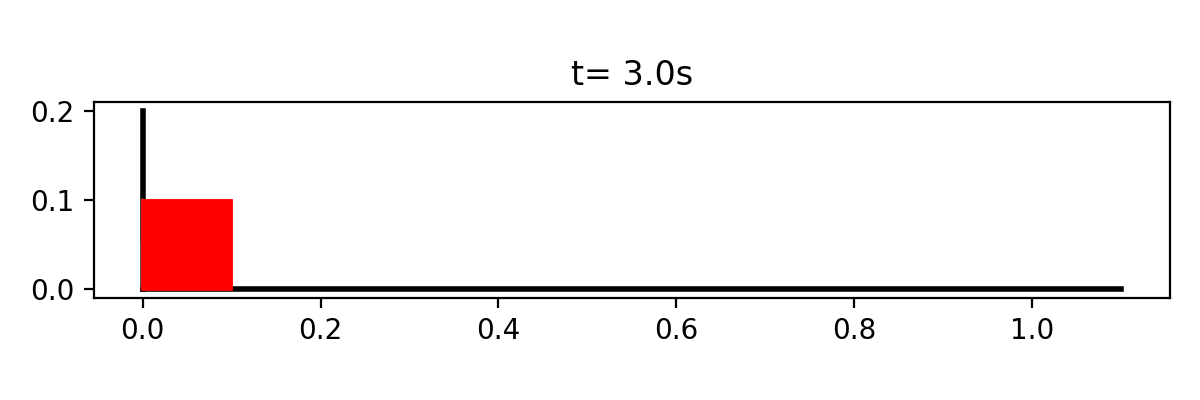
Hybrid ODE Sim
A Python package for simulating systems with both continuous and discrete-time dynamics, such as robots with their control and planning loops.
Code
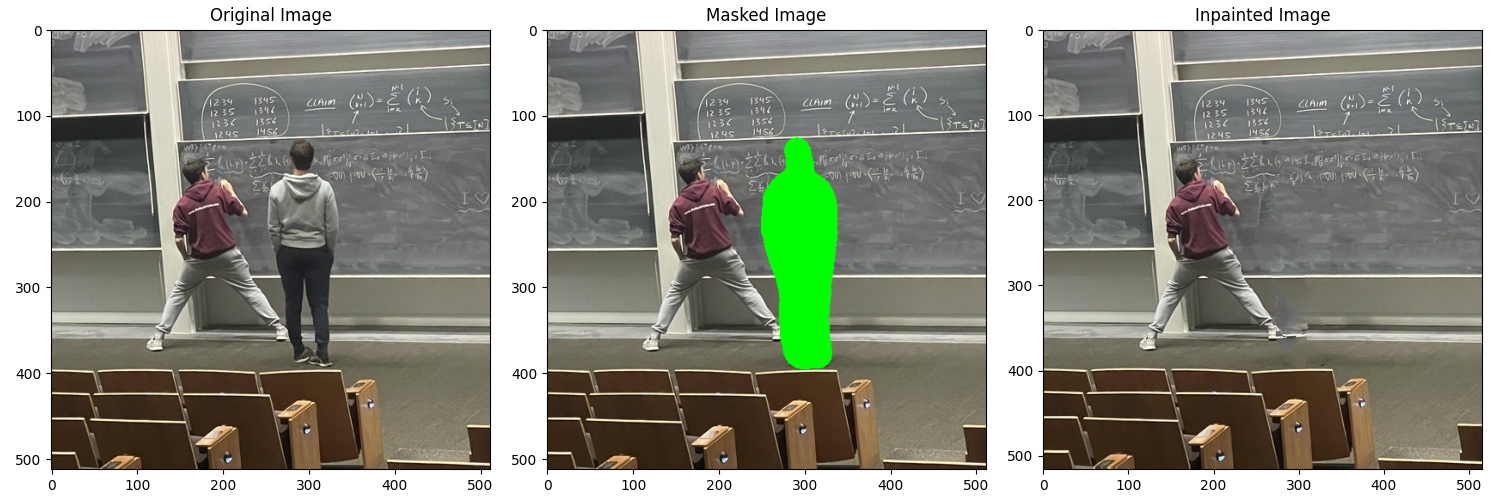
Parallel PatchMatch for Content-Aware Fill
Micah Reich, David Krajewski
15-418 Parallel Computer Architecture and Programming, CMU
Code
Model Predictive Path Integral Control with Learned Dynamics
16-711 Robot Kinematics, Dynamics, and Control, CMU
Paper •
Code
ViperLang Compiler
A compiler for a Lisp-like language, written in Rust.
Code
2021–26
Guidance, navigation, and controls software for TartanAUV, CMU's RoboSub team2022
3rd place of 40 universities at RoboSub 2022 with TartanAUV2022
Teaching Assistant for 15-151/21-128 Mathematical Foundations for Computer Science at CMUComing soon